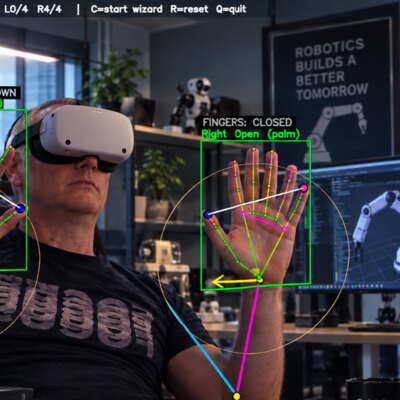
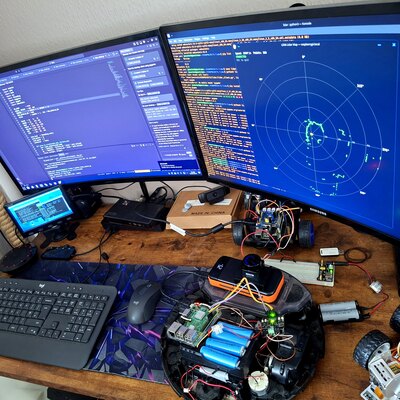
Humanoid autonomy
Teleoperation, leader-follower, and autonomous behaviour on commercial humanoid platforms: Unitree G1, AGIBOT A2.
Over 20 years at the intersection of low-level systems, artificial intelligence, and robotics. Current focus: humanoid teleoperation, quadruped autonomy, and the real-world engineering that makes commercial platforms genuinely useful.
From humanoid teleoperation to bootloaders. A hands-on approach to systems that think, adapt, and get out of the way.
Teleoperation, leader-follower, and autonomous behaviour on commercial humanoid platforms: Unitree G1, AGIBOT A2.
Fleets of robots coordinating in the physical world: swarms, drone-ground teams, shared objectives.
Quadrupeds, LiDAR drones, Raspberry Pi swarms. Hands-on experiments where AI meets the real world.
Linux from scratch, bootloaders, and kernel-level work that pushes what a modern OS can do.
From Unitree G1 teleoperation to Go2 quadruped autonomy and LiDAR-mapping drones.
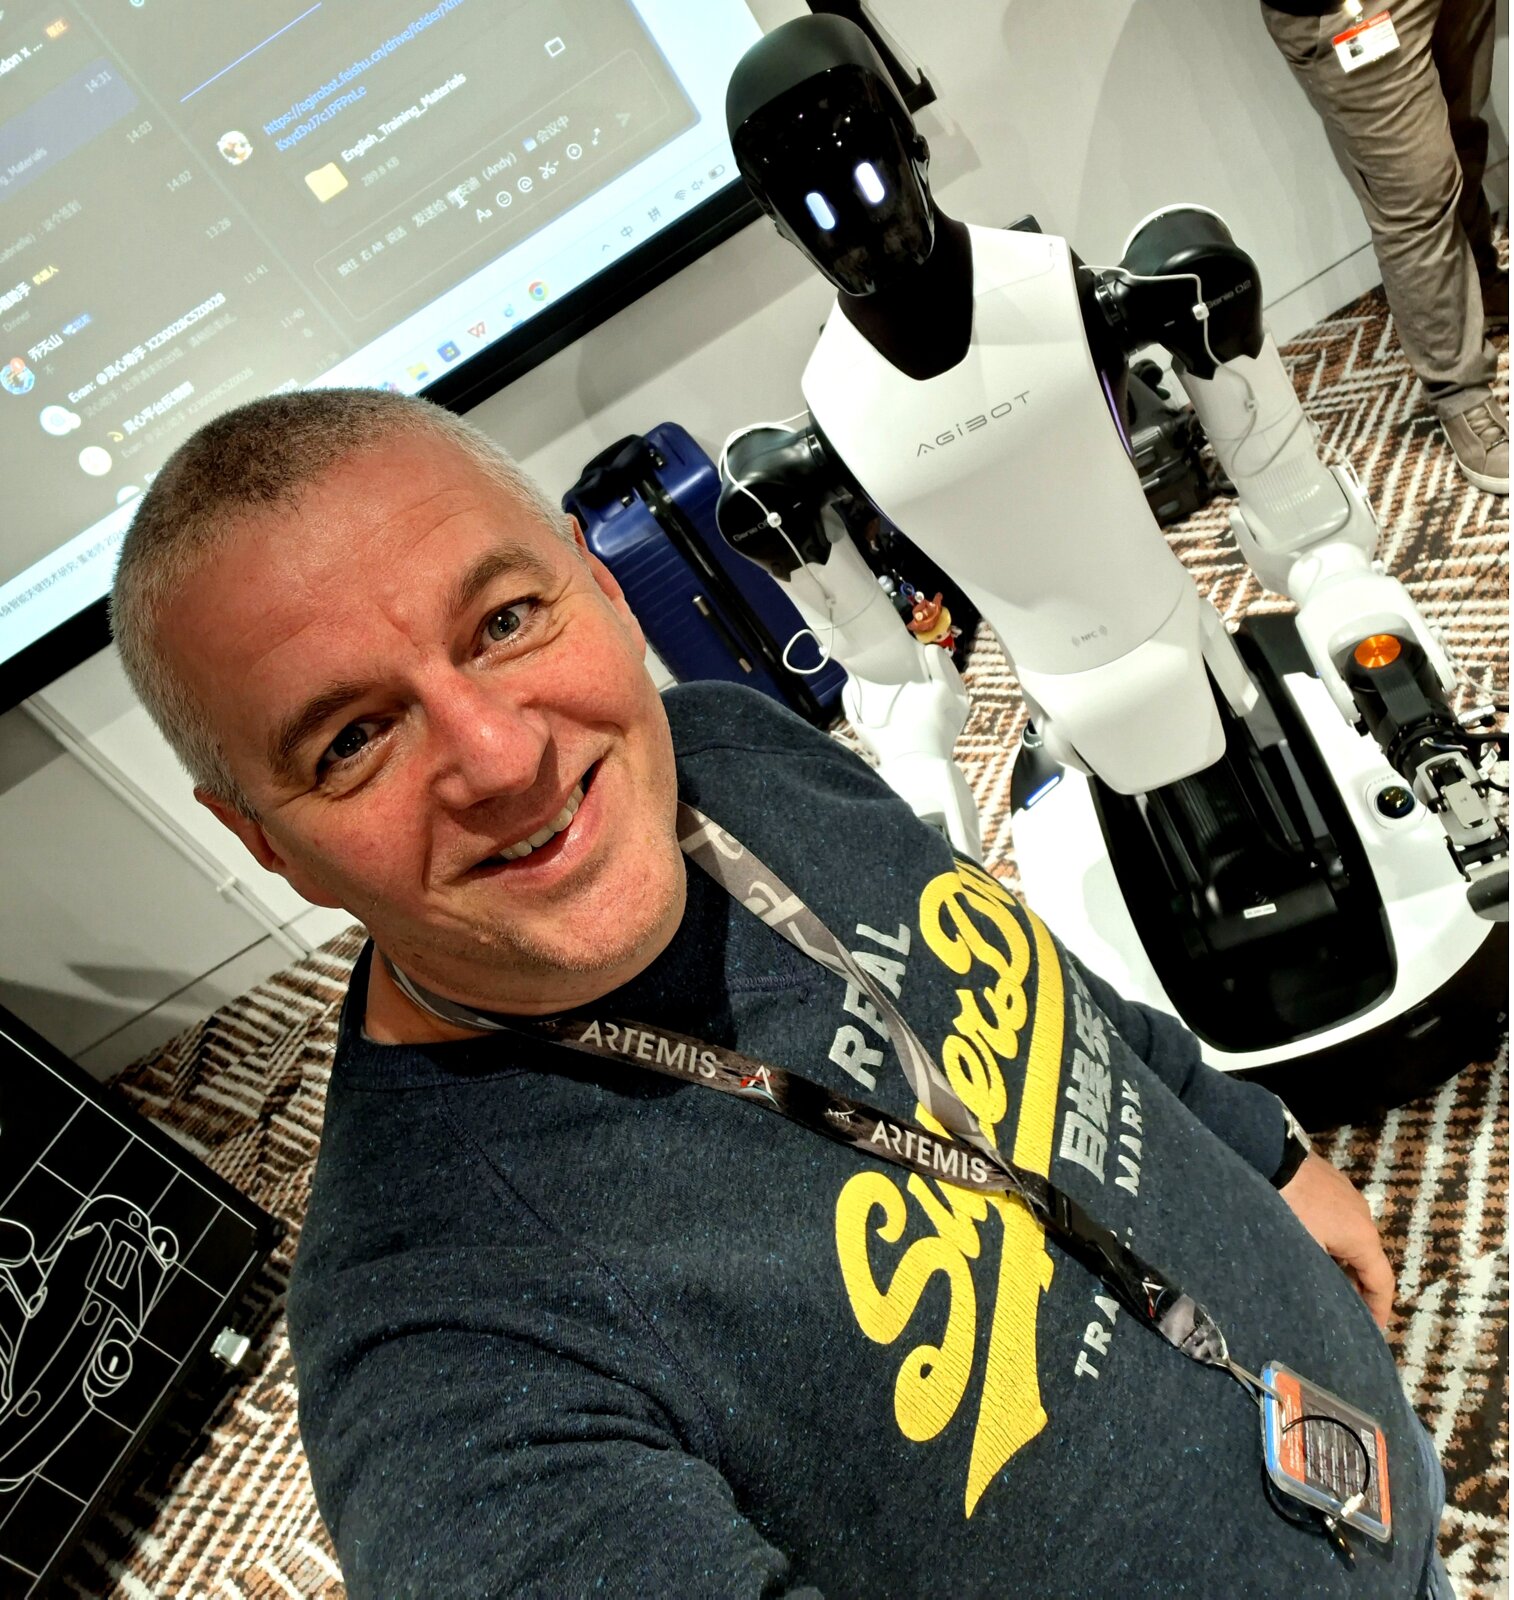
Real-time arm and hand tracking driving Unitree G1 and AGIBOT humanoids. Groundwork for shared autonomy.
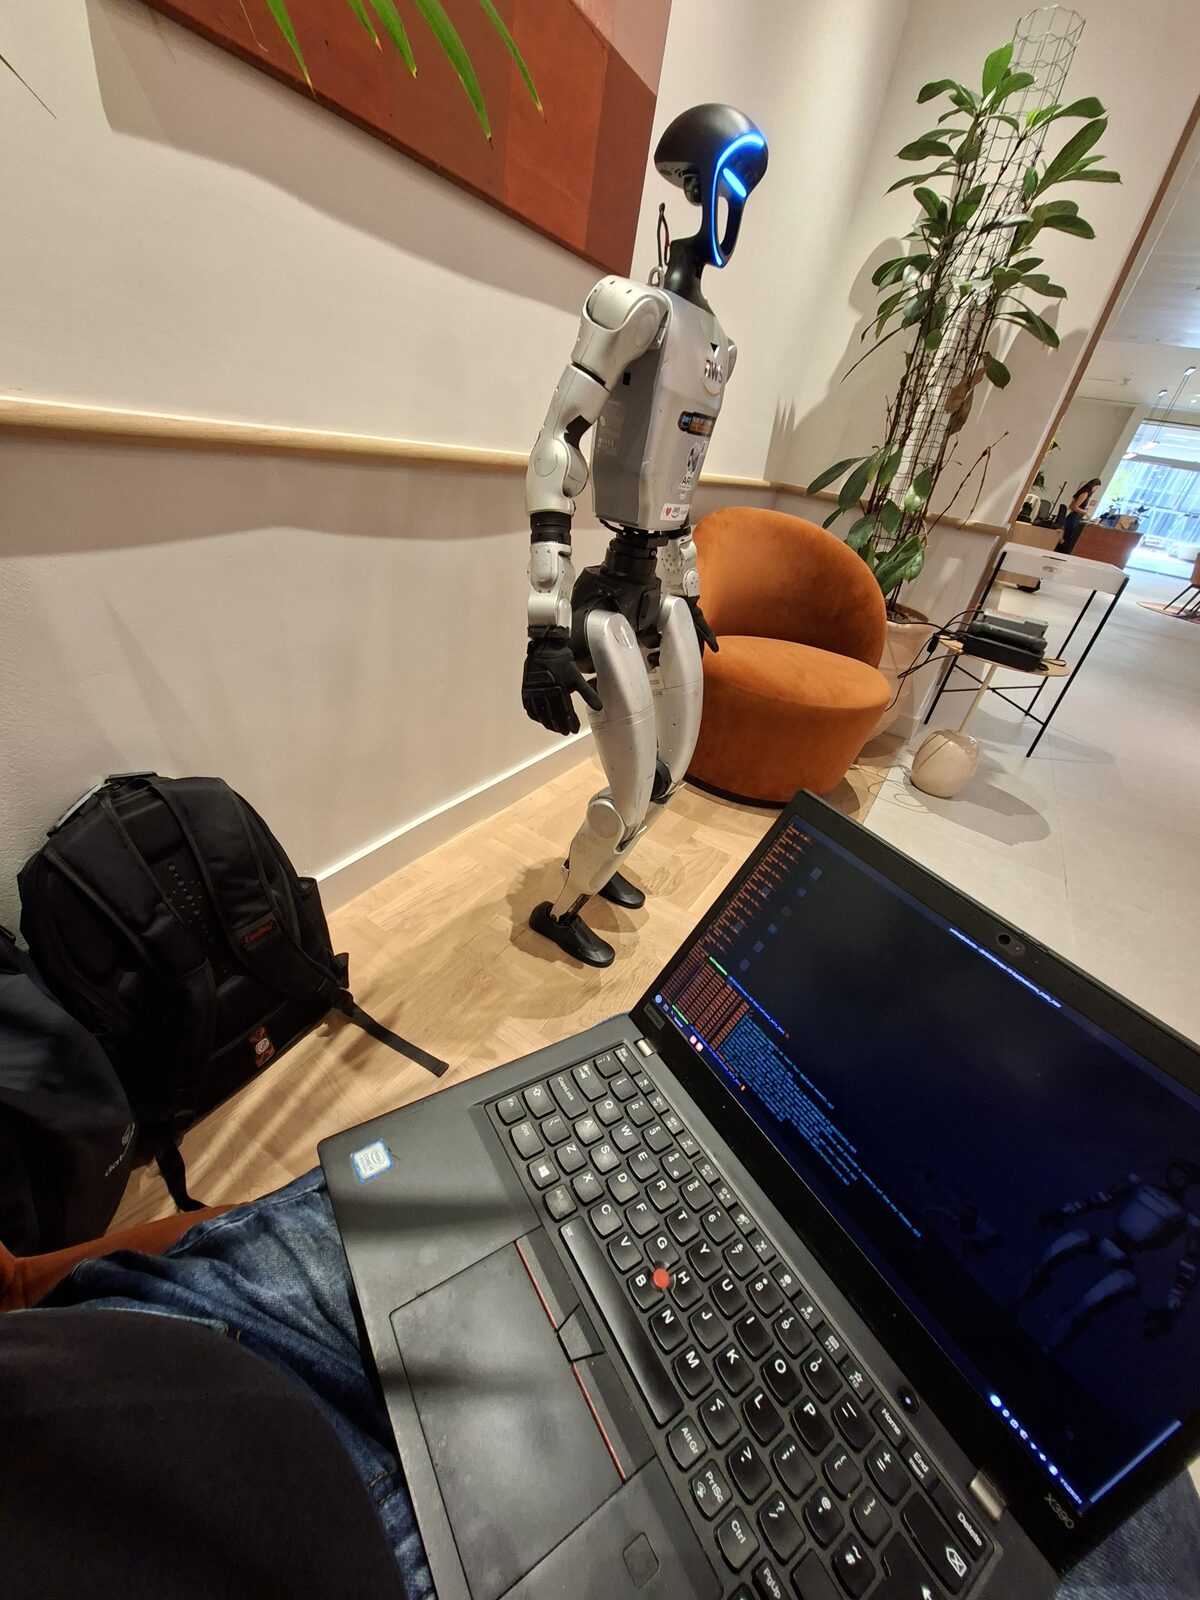
Perception, planning, and recovery on walking humanoids. Robust in human environments, not just mocap stages.
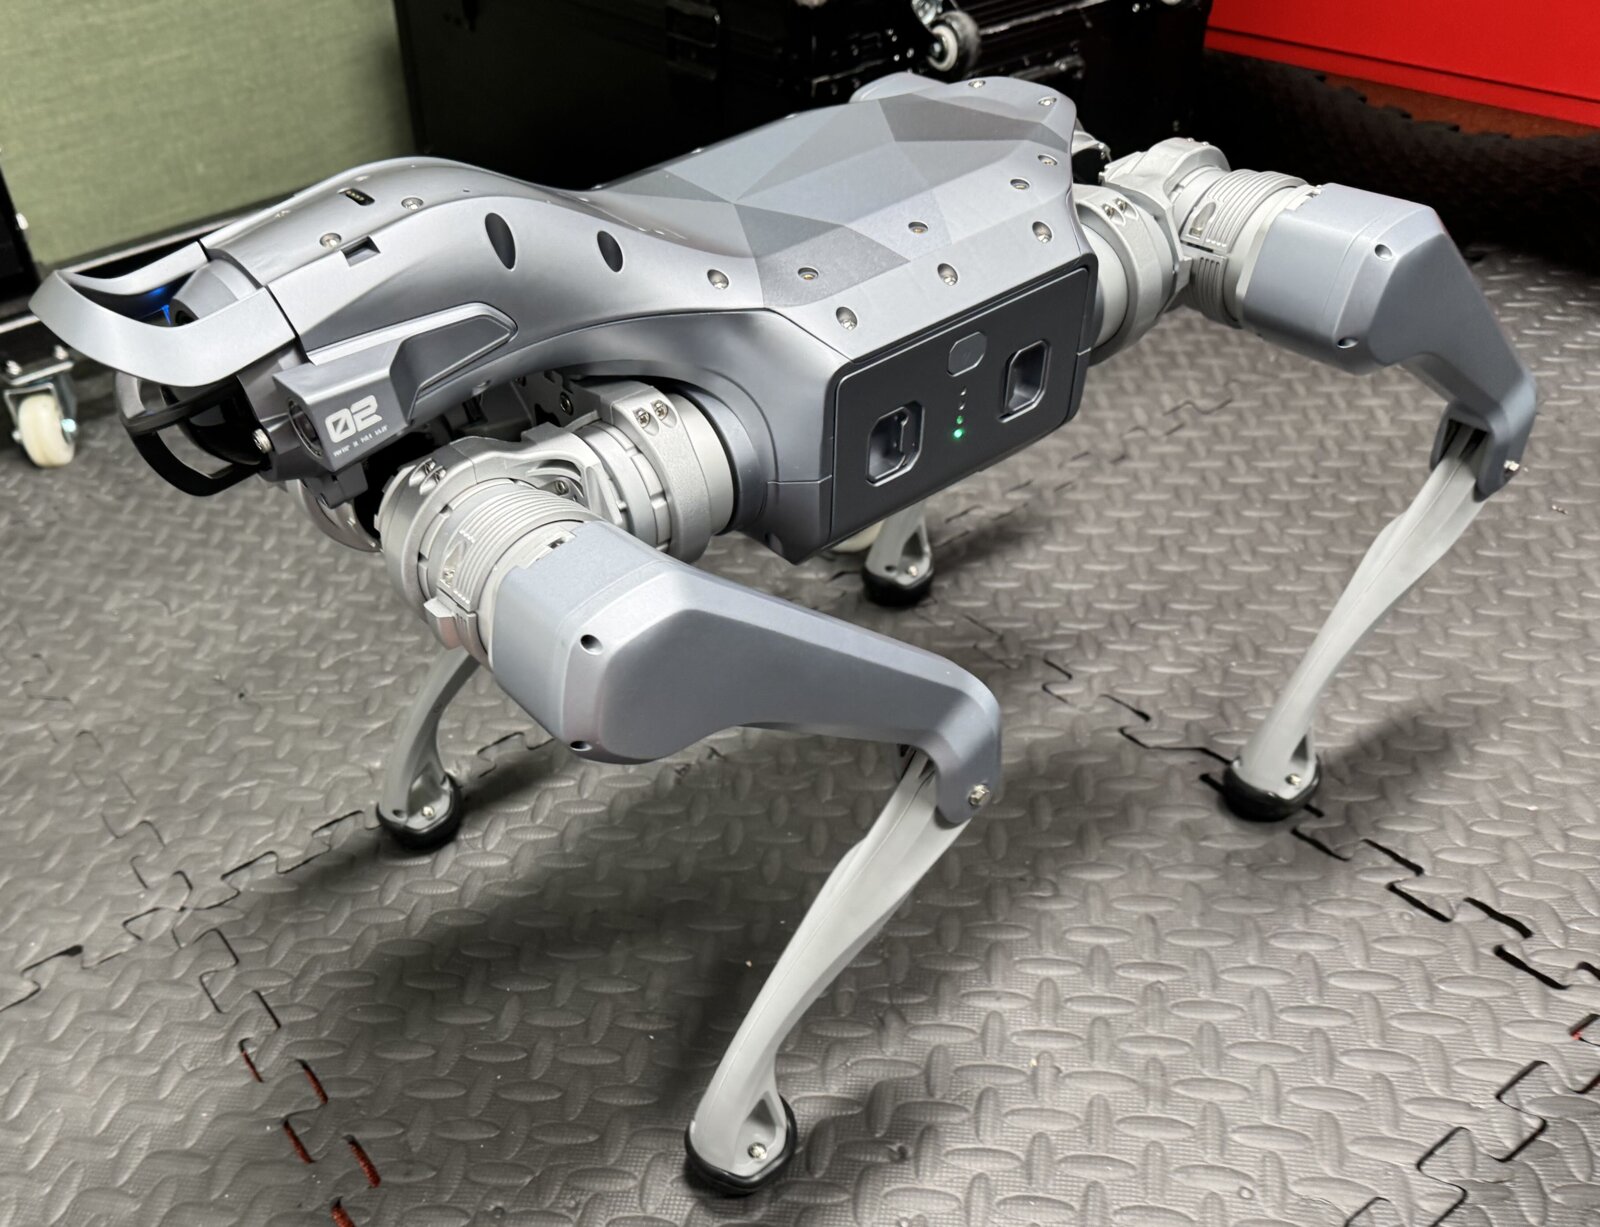
Inspection, construction surveying, and civil engineering. Where legs beat wheels and where they don't.
Seamless communication and coordination between fleets of autonomous robots pursuing shared goals.
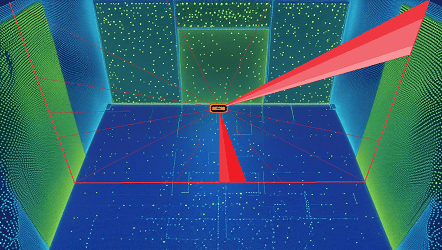
Reactive flight control at >=10 Hz, building 3D slice maps while navigating unknown environments.
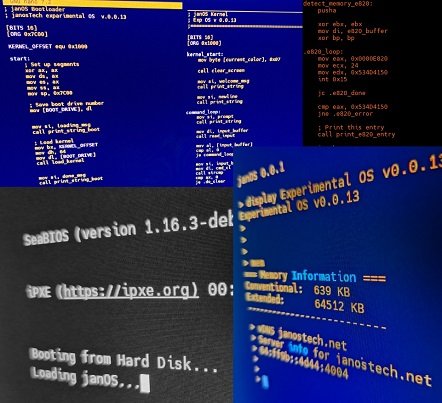
Boot, kernel, and assembly-level experiments. What a modern OS could look like.
Humanoid autonomy, multi-robot systems, applied AI. If it's interesting, I want to hear about it.
janos@janostech.net